Samantha Caballero

Samantha Caballero

Robotics | Validation, Simulation & Control Systems

Robotics engineer with a background in automotive engineering, specialized in control systems, simulation and validation. From modelling to control system design to structured validation against real hardware. I build autonomous systems end to end: ROS, localization, motion planning. Recently, I finished the IFROS Erasmus Mundus Master.

  • EducationMSc Intelligent Field RoboticsBSc Automotive Engineering
  • ExperienceRobotics Perception @ Beta Robots, ESSimulation & Validation @ Haulotte, FR
  • LanguagesES · EN · FR

Experience

  1. February 2026 — August 2026

    Robotics Perception Engineer

    Beta Robots Barcelona

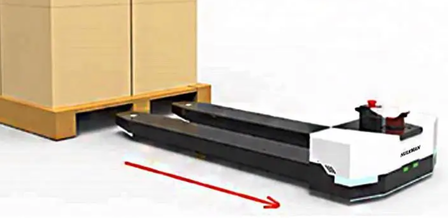
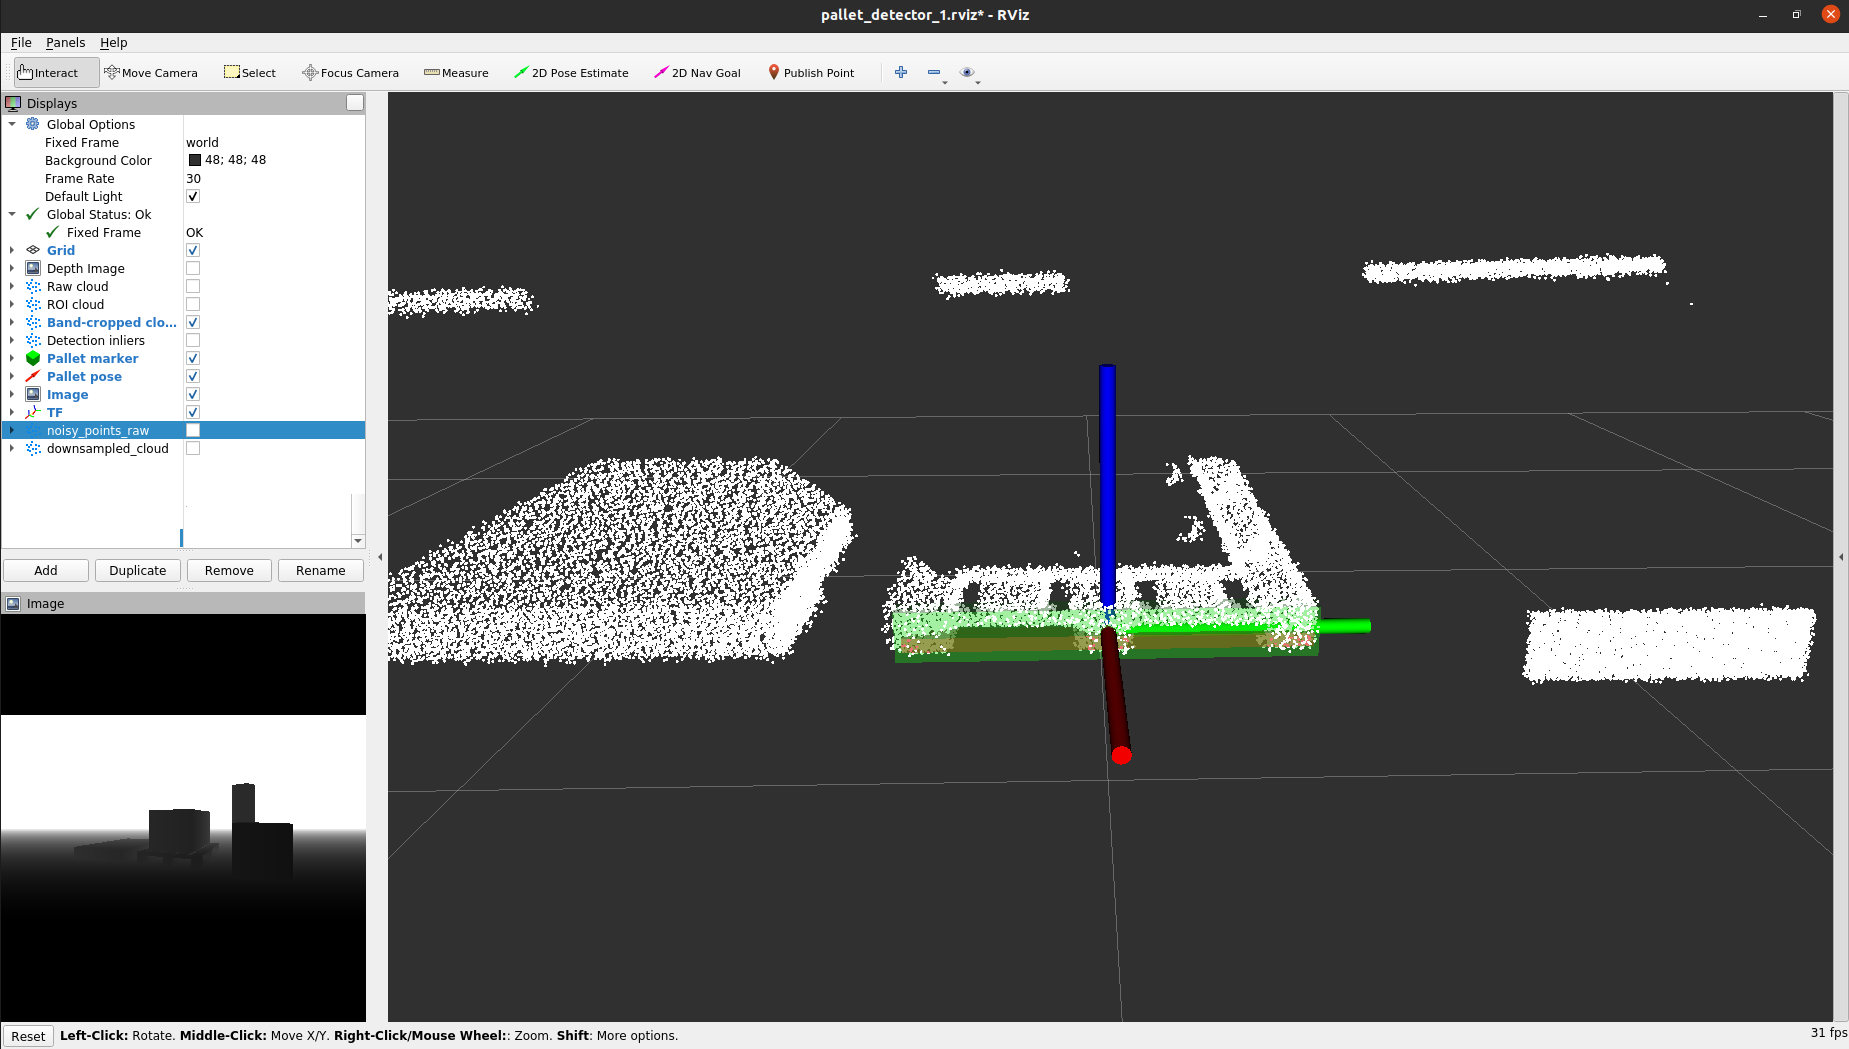
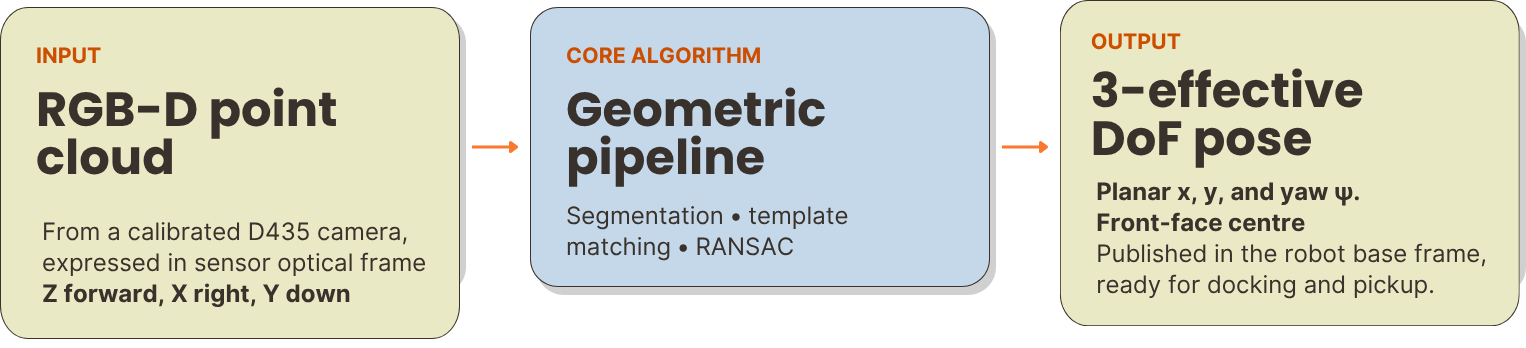
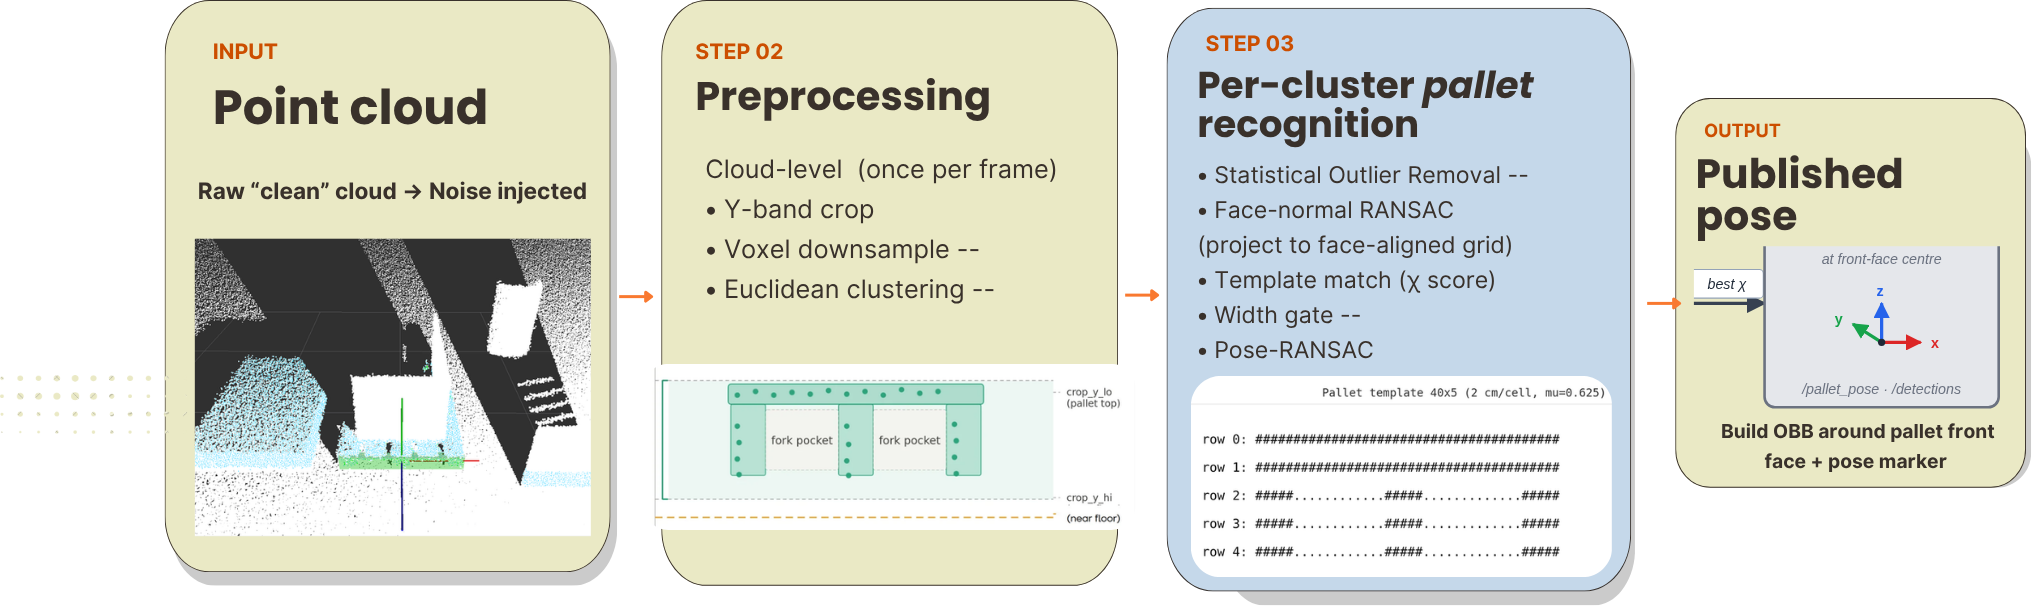
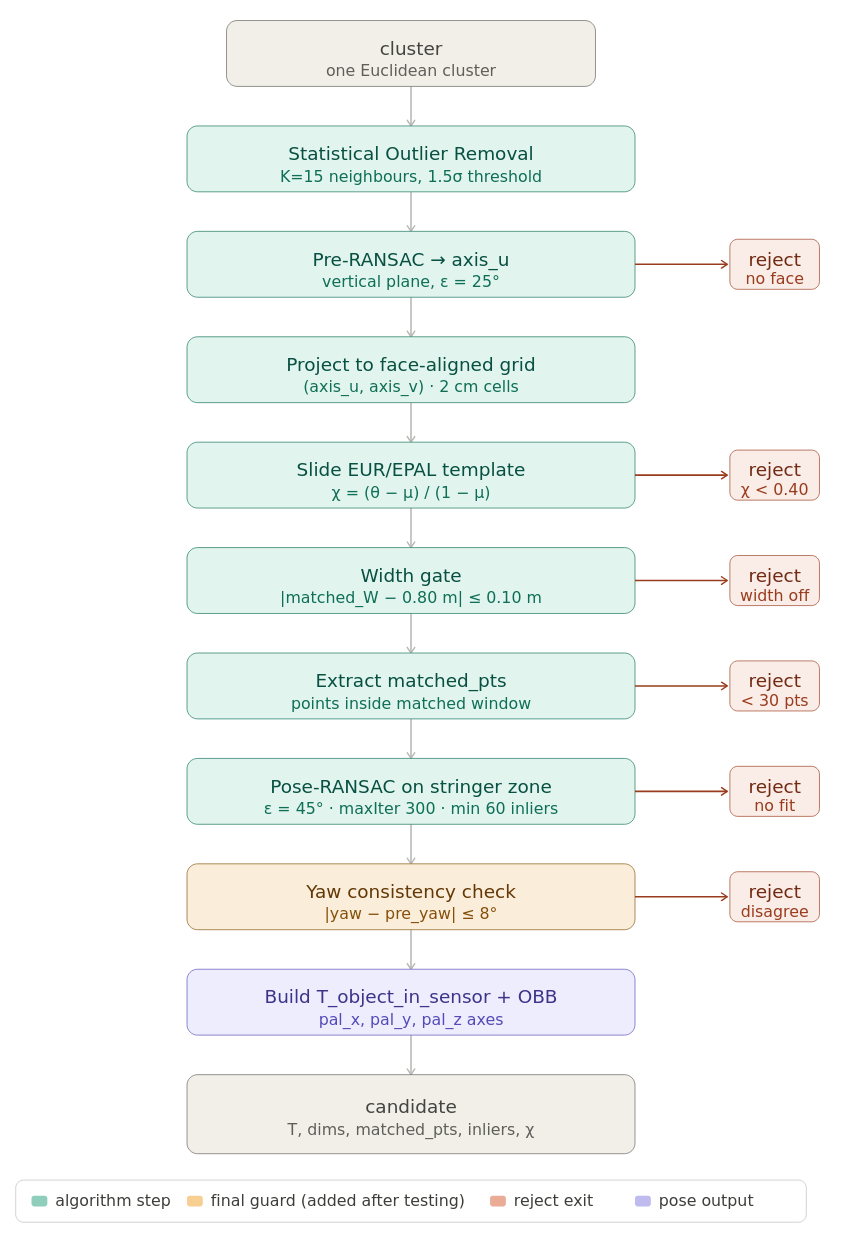
    Delivered a classical geometric RGB-D perception pipeline for autonomous pallet pickup by industrial mobile robots, recovering the pallet pose from depth-sensor processing, and integrated it as a feature of Duna, the company's robot software product (see the demo).

    • Built test cases to validate the pipeline across scenarios in simulation, with further rosbag validation.
  2. 2021 — 2023

    Control & Simulation Engineer (R&D)

    Haulotte Lyon, France

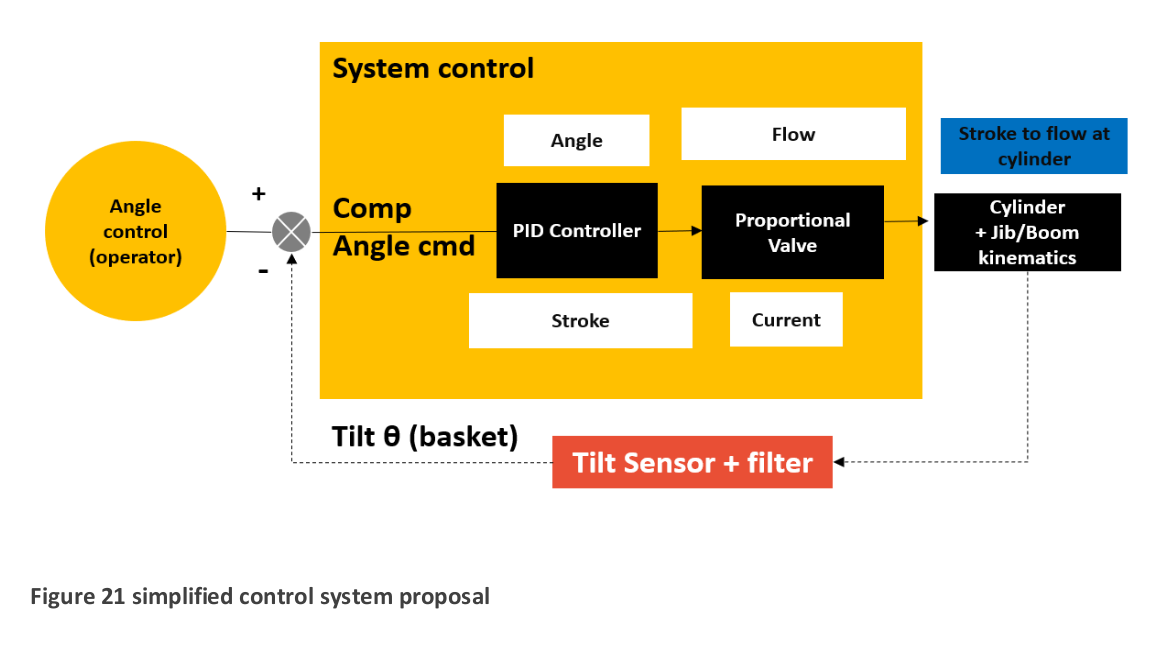
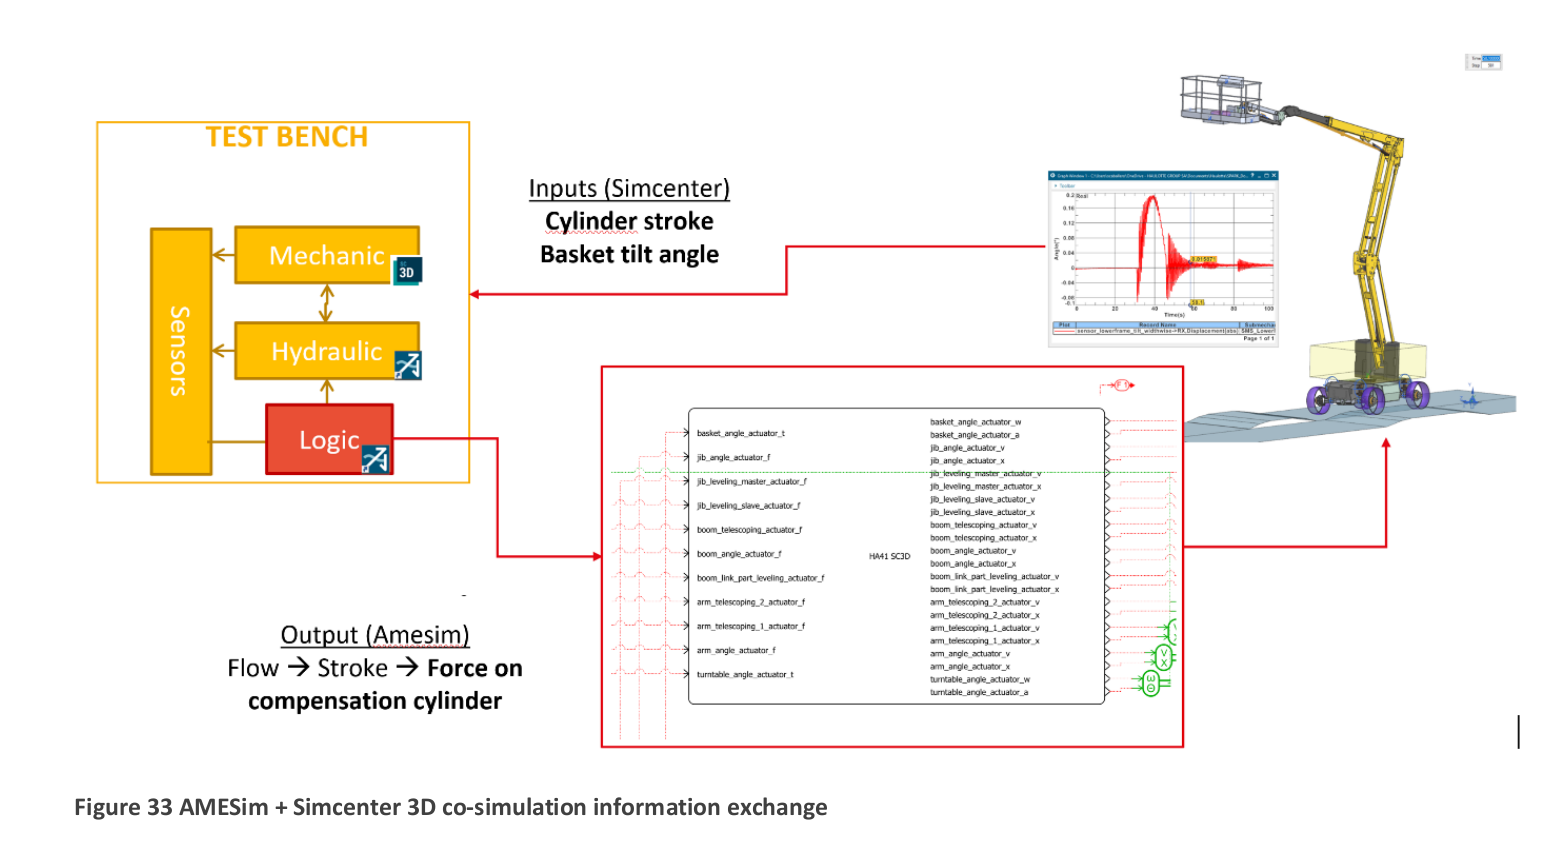
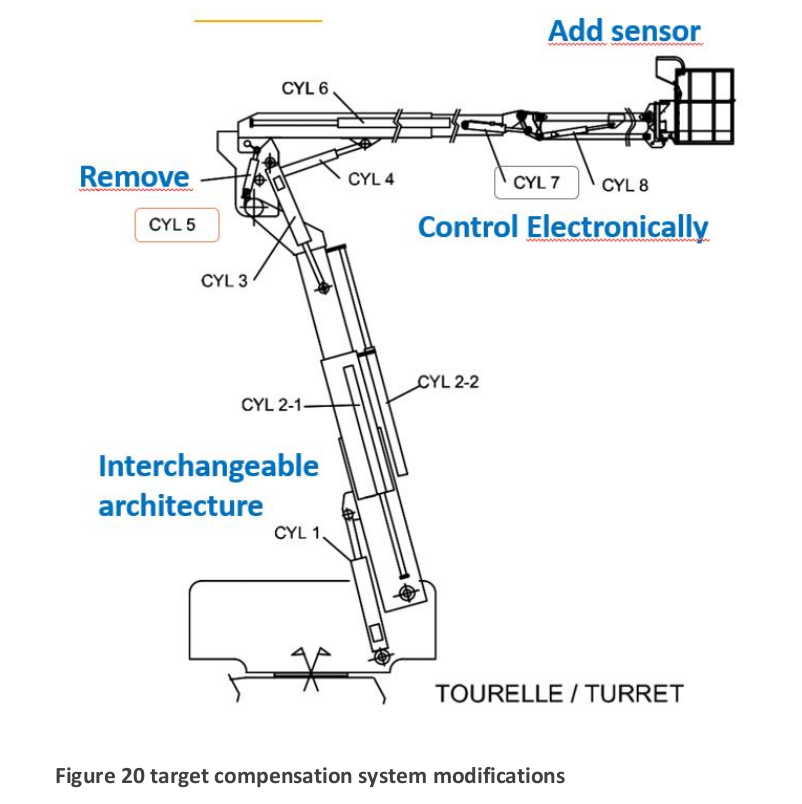
    Developed a tilt-compensation control system for articulated boom lifts: multi-domain modelling in Simcenter AMESim, co-simulation with Simcenter 3D, PID control design, and FMI export to Unity for VR validation. Ran physical stability test campaigns on real machines to derive acceptance criteria, and contributed to FMEA on the new architecture.

Projects

P01 · MSc Thesis · RGB-D Perception

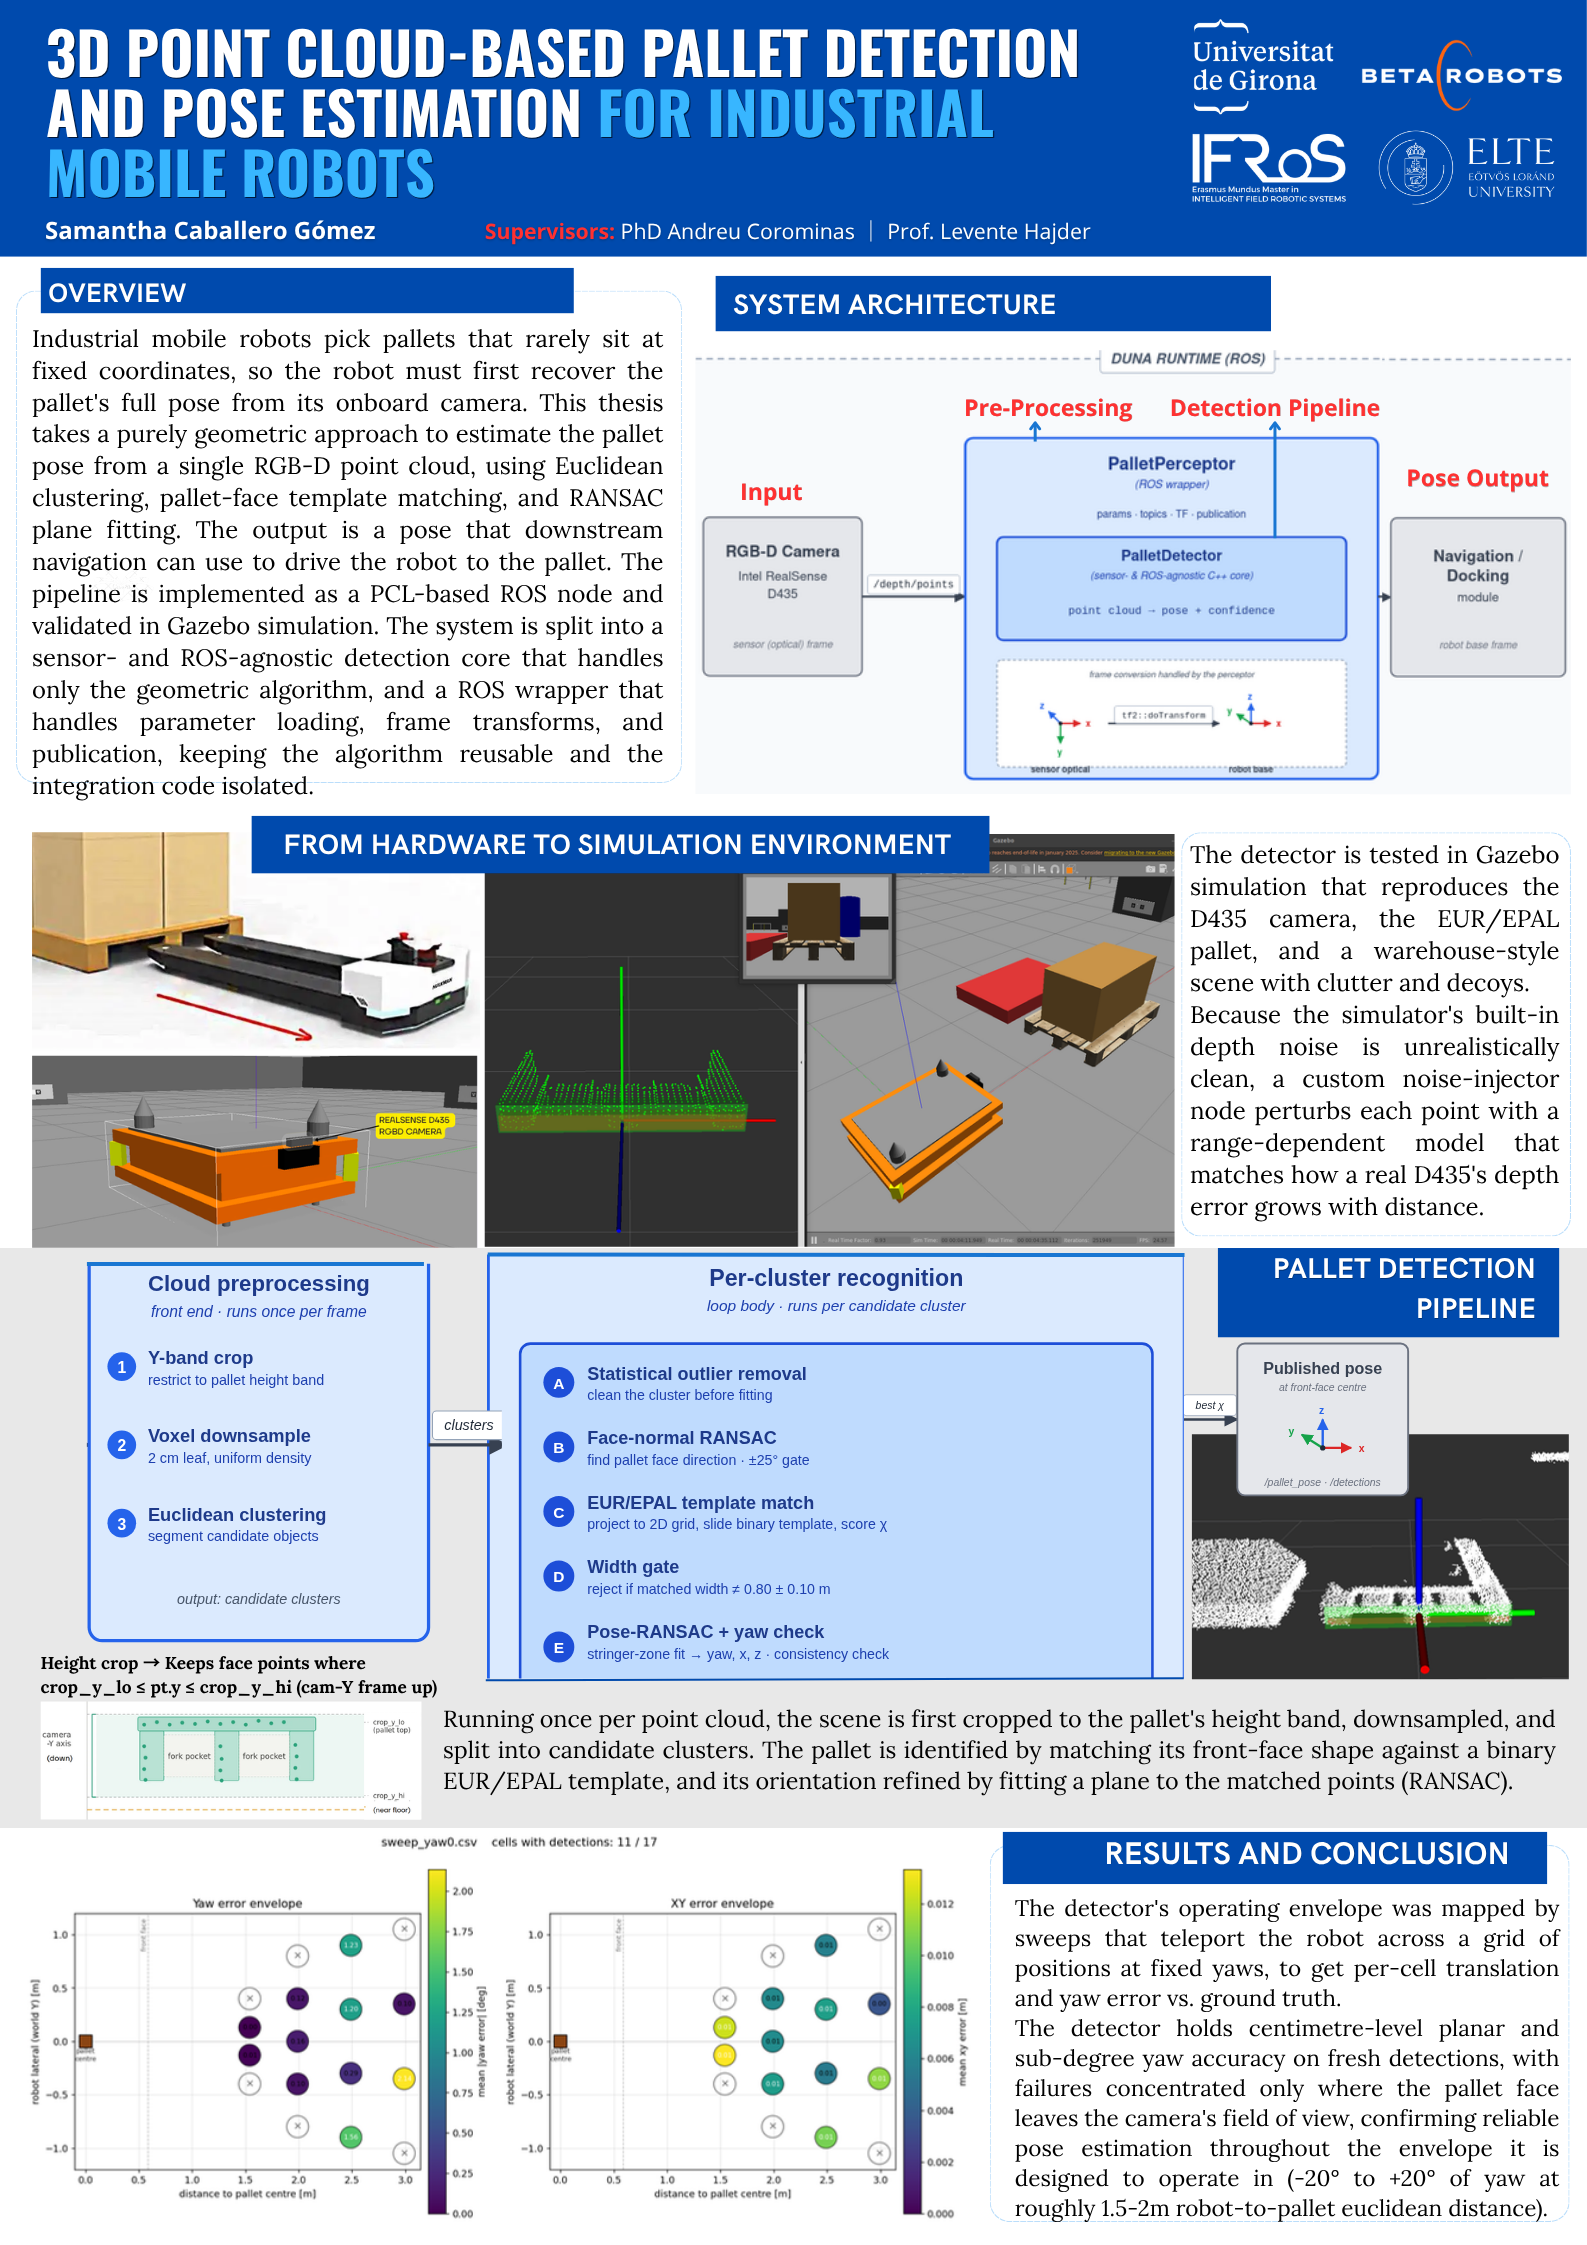
3D Pallet Detection & Pose Estimation for Industrial Mobile Robots

  • C++
  • PCL
  • ROS
  • RANSAC
  • Gazebo
Poster

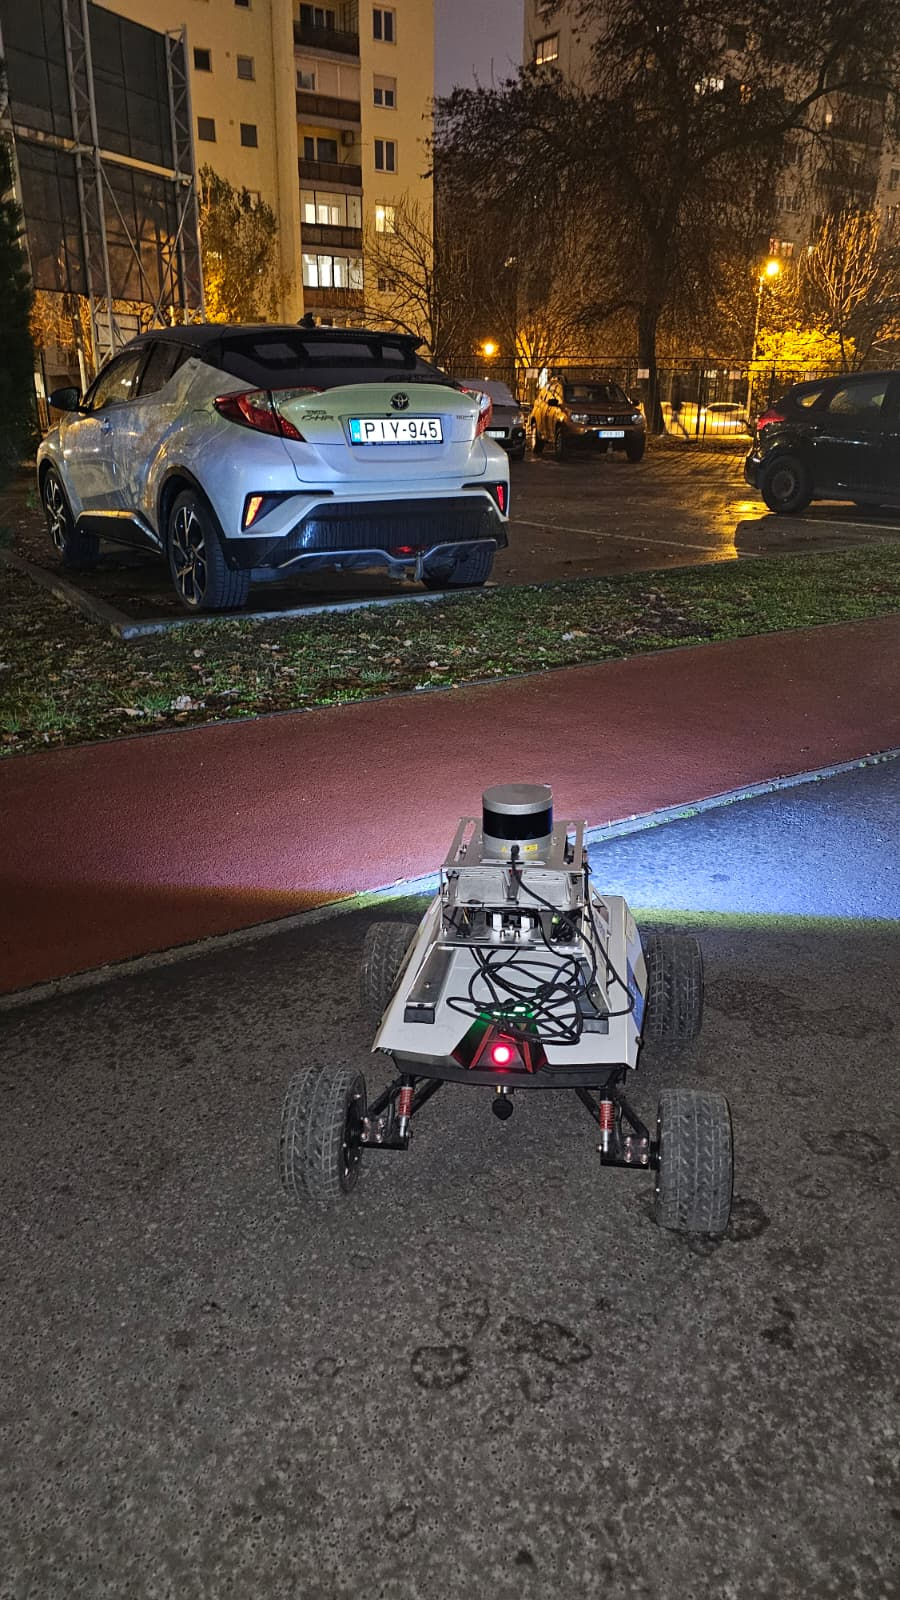
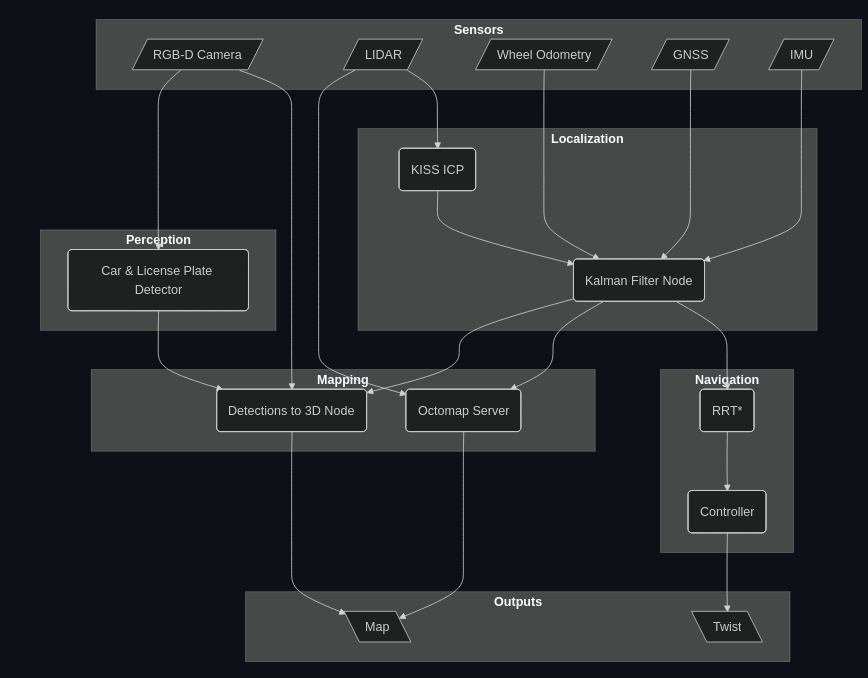
P02 · AgileX Scout · SLAM

Parking Inspector

  • ROS
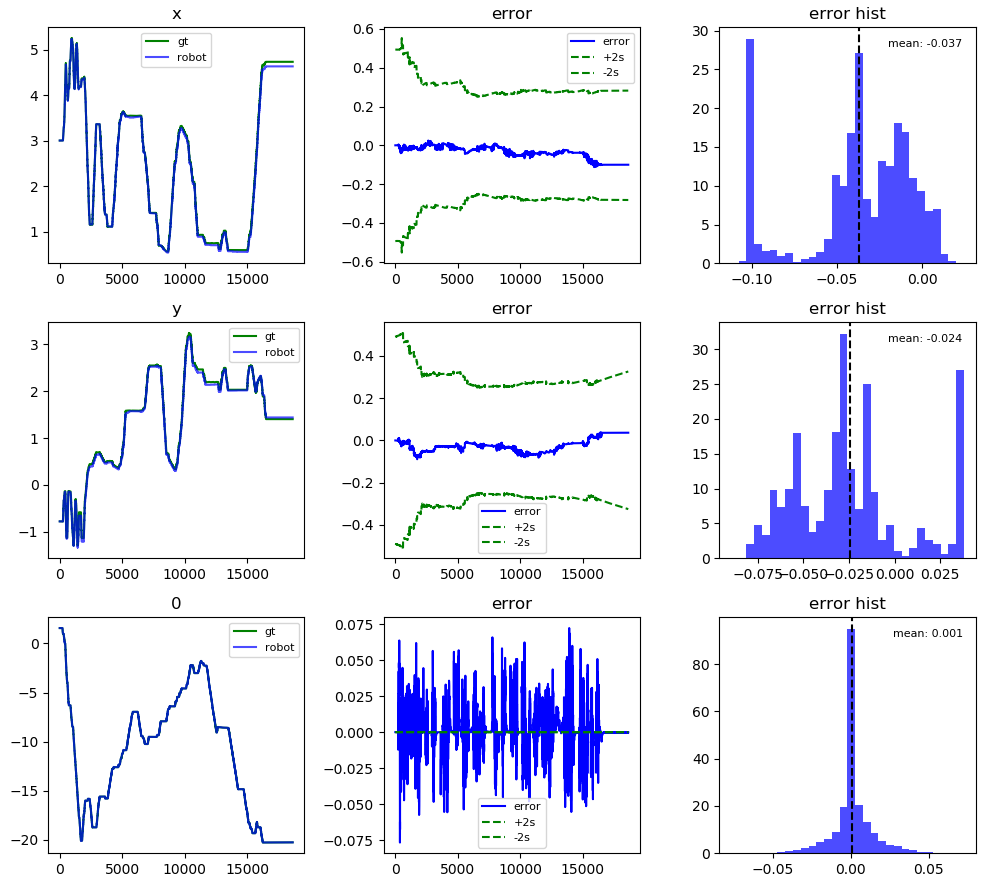
  • EKF
  • OctoMap
  • RRT*
  • YOLO
  • Python
GitHub

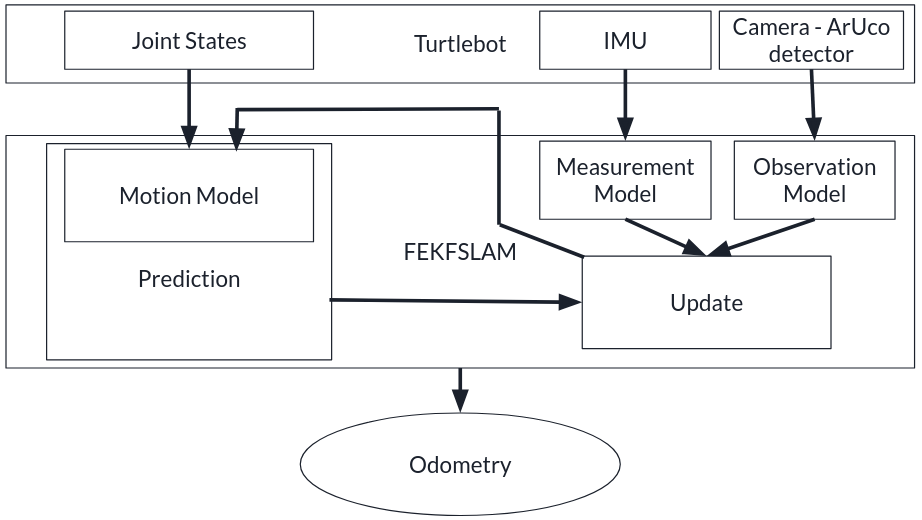
P03 · TurtleBot · SLAM

Feature-Based EKF SLAM

  • ROS
  • EKF
  • Sensor fusion
  • Python
GitHub

P04 · Manipulator · Control

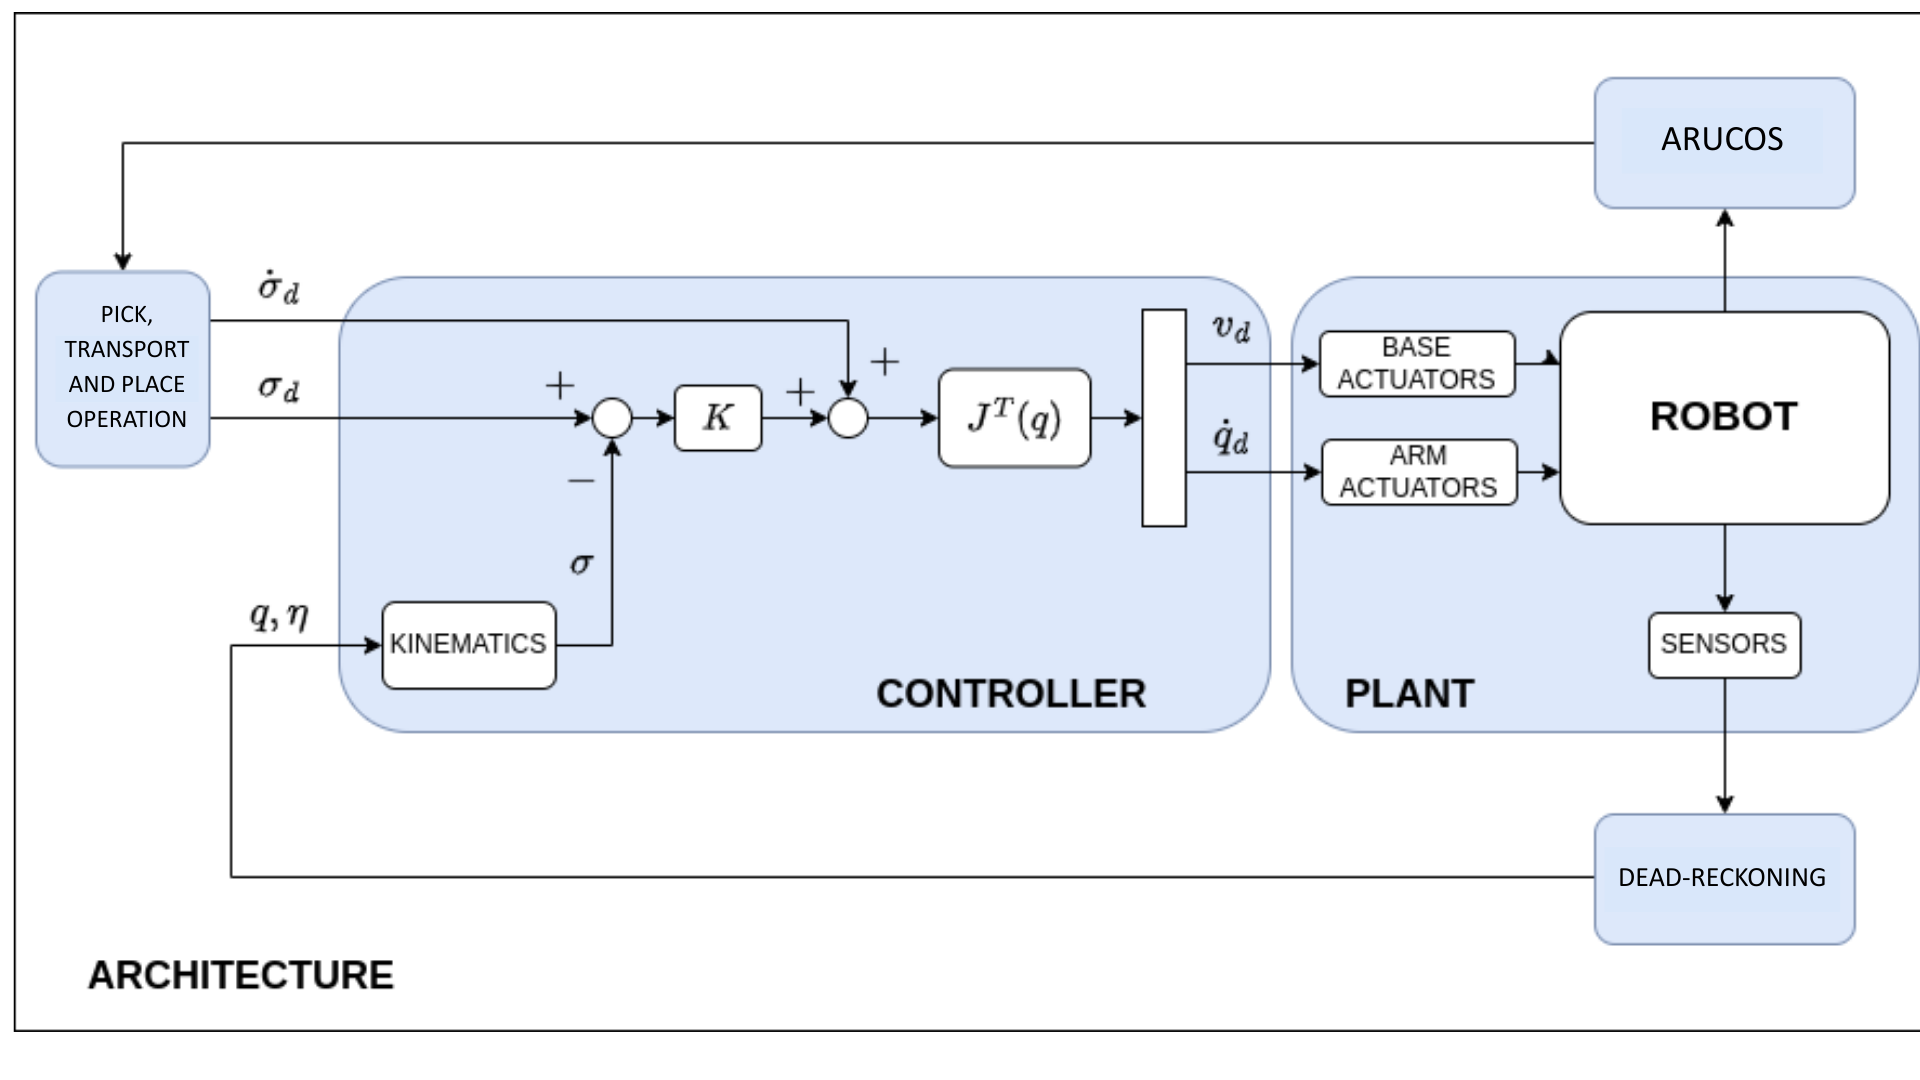
Task-Priority Kinematic Control

  • ROS
  • Kinematic control
  • Python
GitHub

P05 · Stäubli TX60 · Industrial Arm

Stäubli TX60 Assembly Cell

  • Manipulation
  • Industrial Robotics
  • Trajectory Control

P06 · Stäubli TS60 · SCARA

Stäubli TS60 SCARA Pick-and-Place

  • SCARA
  • Pick-and-Place
  • Industrial Robotics

P07 · TurtleBot · Navigation

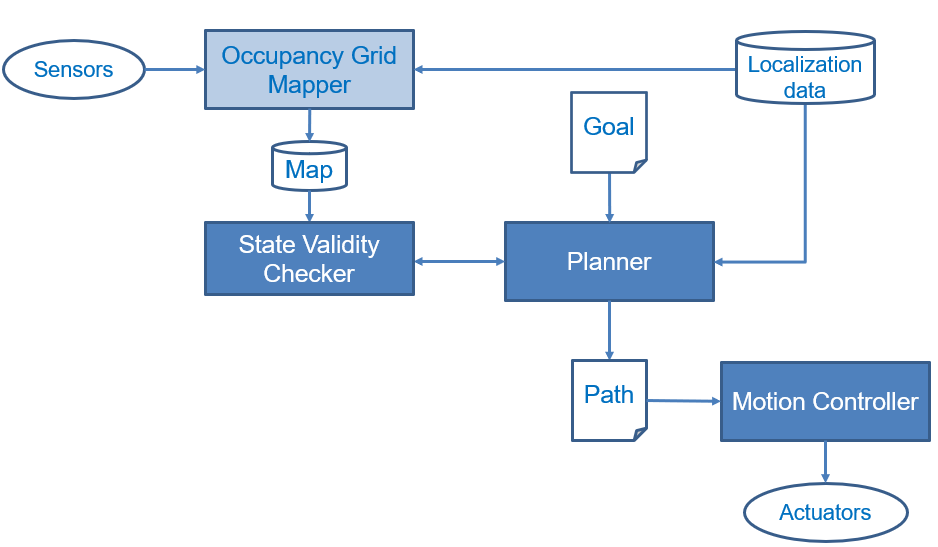
Map-Based RRT Planning & Reactive Control

  • ROS
  • RRT
  • Motion planning
  • Python
GitHub

P08 · Perception · ML

Custom CNN Object Detection

  • PyTorch
  • CNN
  • YOLO
  • WandB
GitHub

P09 · TurtleBot · Coverage

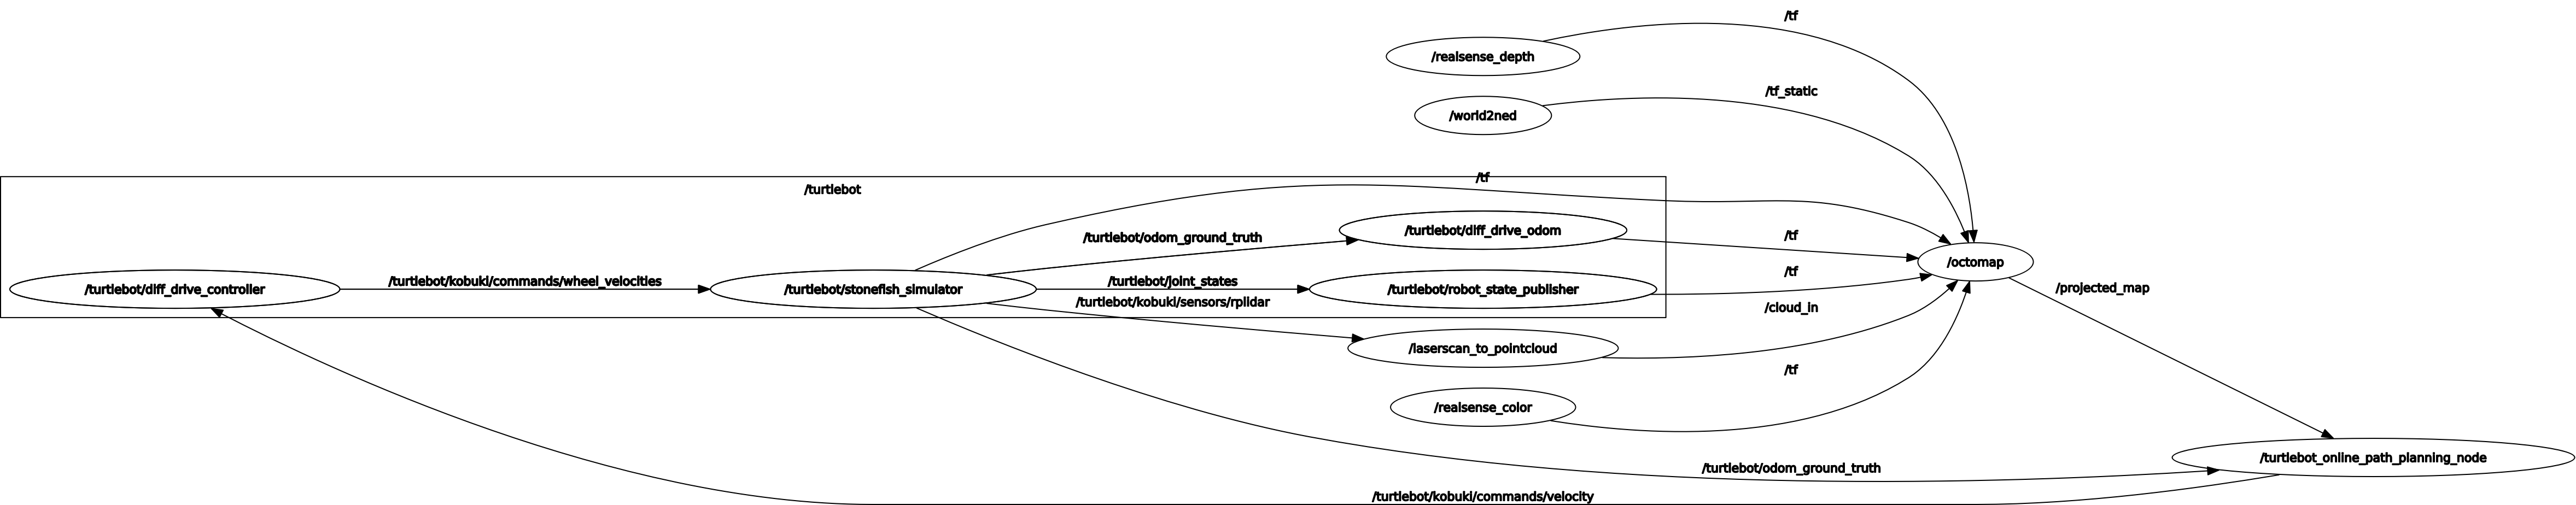
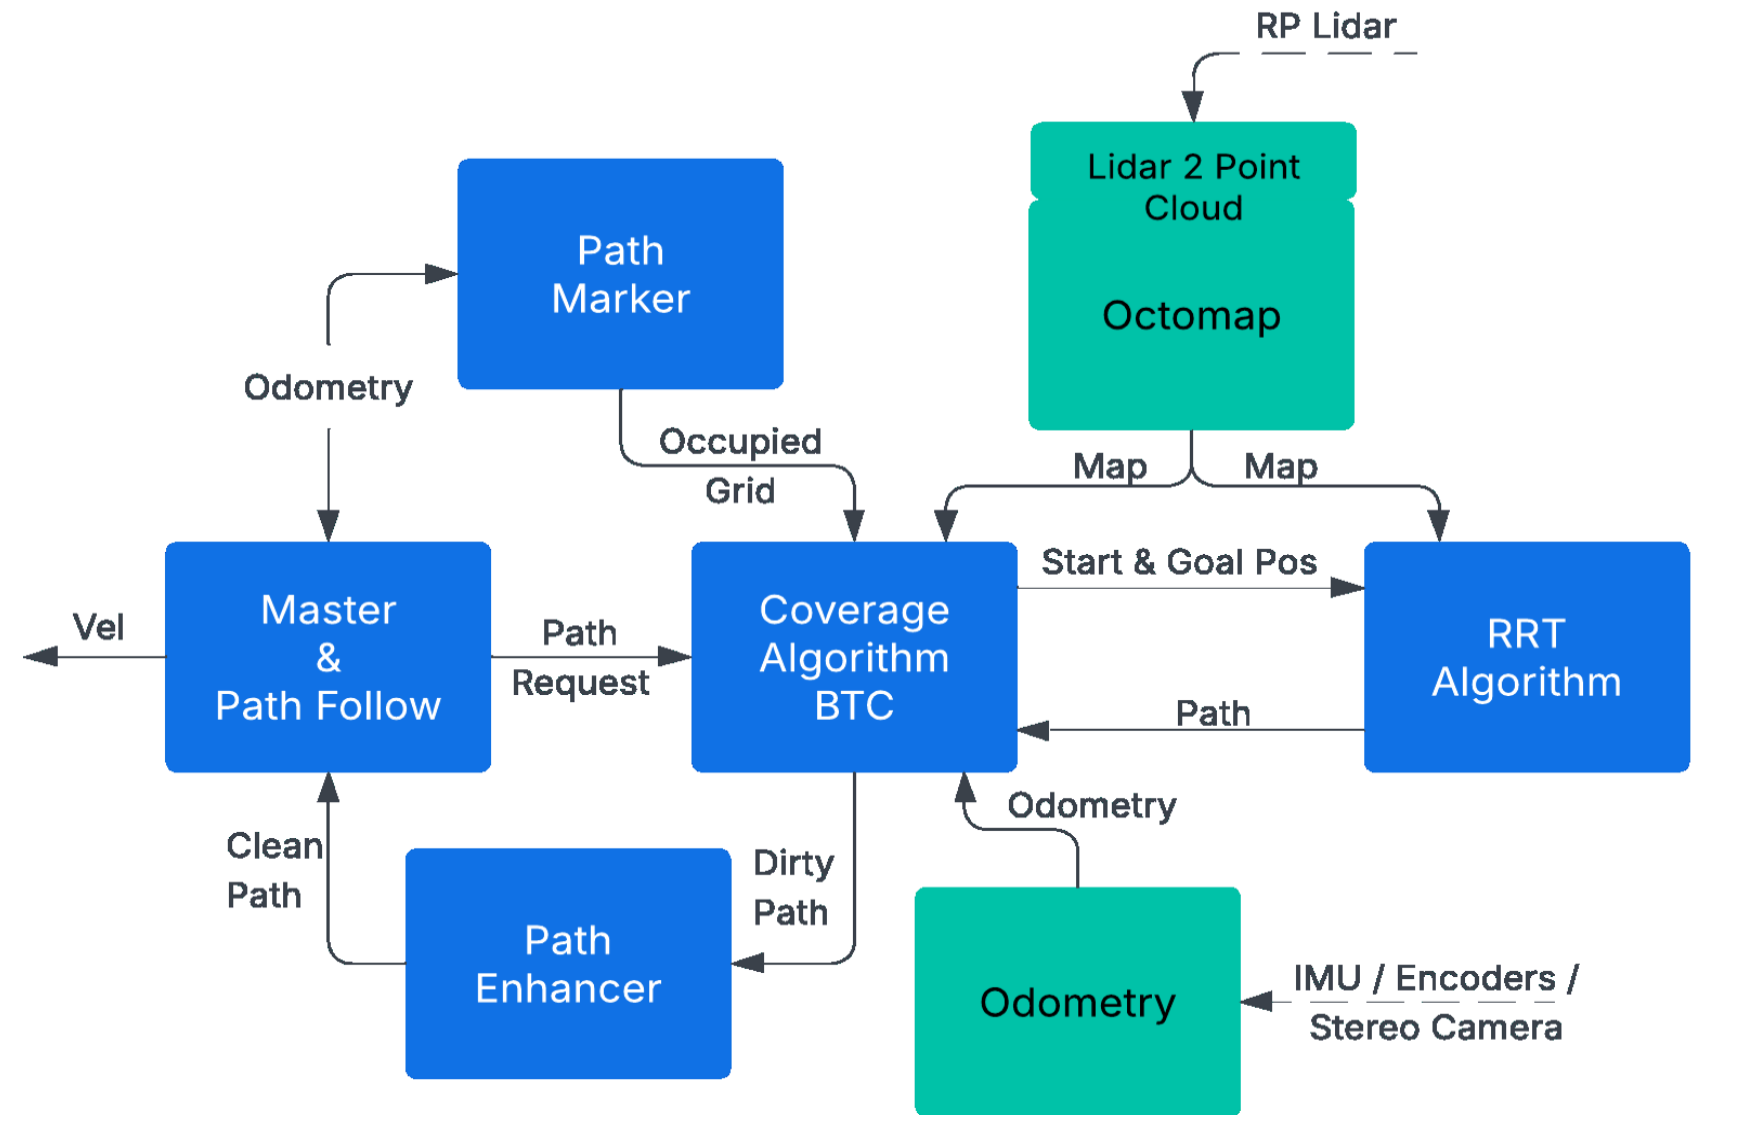
Online Coverage Path Planning

  • ROS
  • Python
  • RRT
  • OctoMap

Skills

Validation

  • V&V
  • FMEA
  • Root-cause analysis
  • Test campaigns
  • Test automation
  • CI

Control & simulation

  • Control systems
  • PID
  • Simcenter AMESim
  • Simcenter 3D
  • MATLAB/Simulink
  • FMI/FMU
  • Unity

Robotics

  • ROS
  • SLAM
  • EKF
  • Motion planning
  • Perception
  • AMRs

Programming

  • Python
  • C++
  • Linux
  • Git
  • Docker
  • PyTorch
  • OpenCV